Your Cart
Loading

Electronics Setup Guide - Half-tracks

Required Components

You will need:

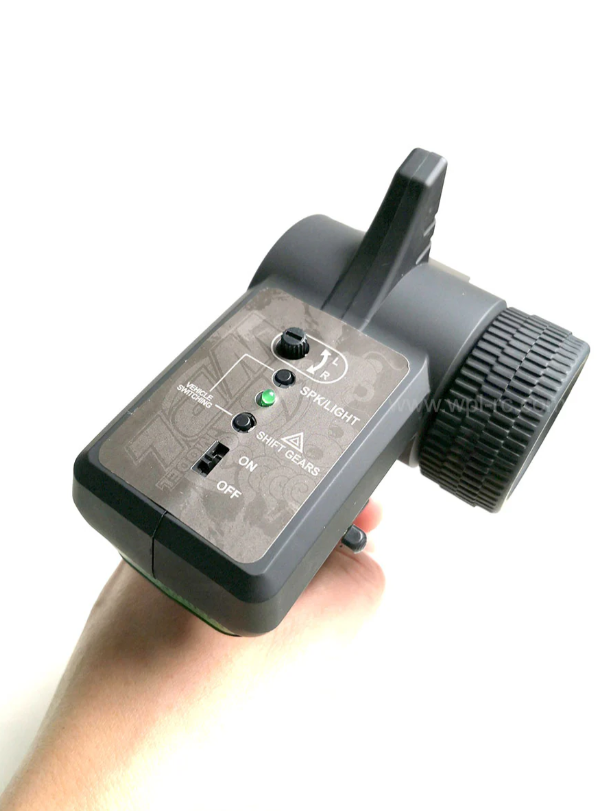
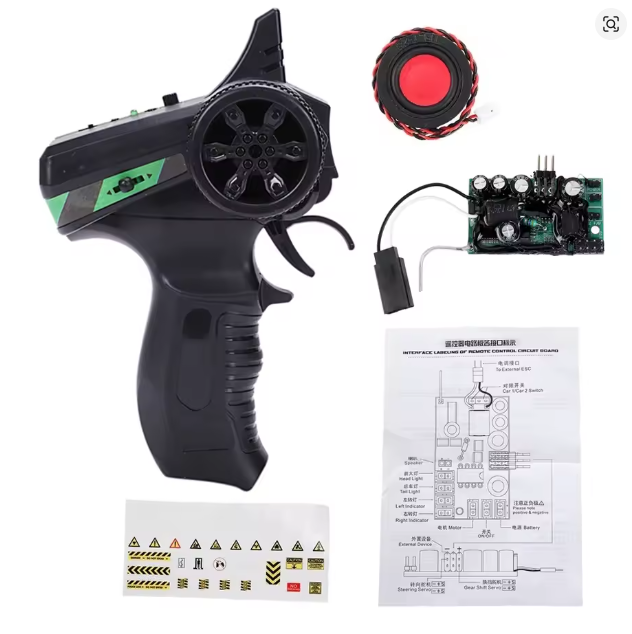
  • R.E.S. V3 transmitter, receiver and speaker by WPL (commonly available on AliExpress and from local RC hobby stores)
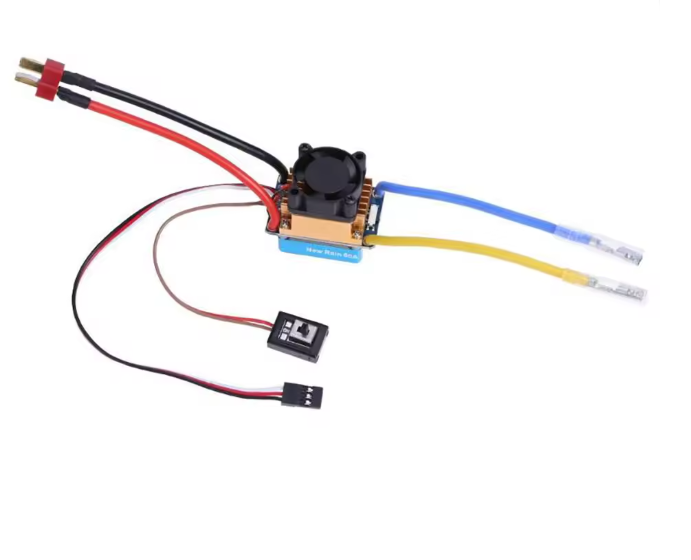
  • ESC for brushed motors (I personally use a 3S 60A ESC)
  • Small slide switch
  • LED lights: Red LEDs for rear lights, Orange LEDs for turn signals, Warm white LEDs for front lights
  • Dual channel servo mixer
  • Y servo cable
  • 2x JST-SH cables
  • 4x 2-pin DuPont cables
  • Soldering iron
  • Wires


Basic Wiring

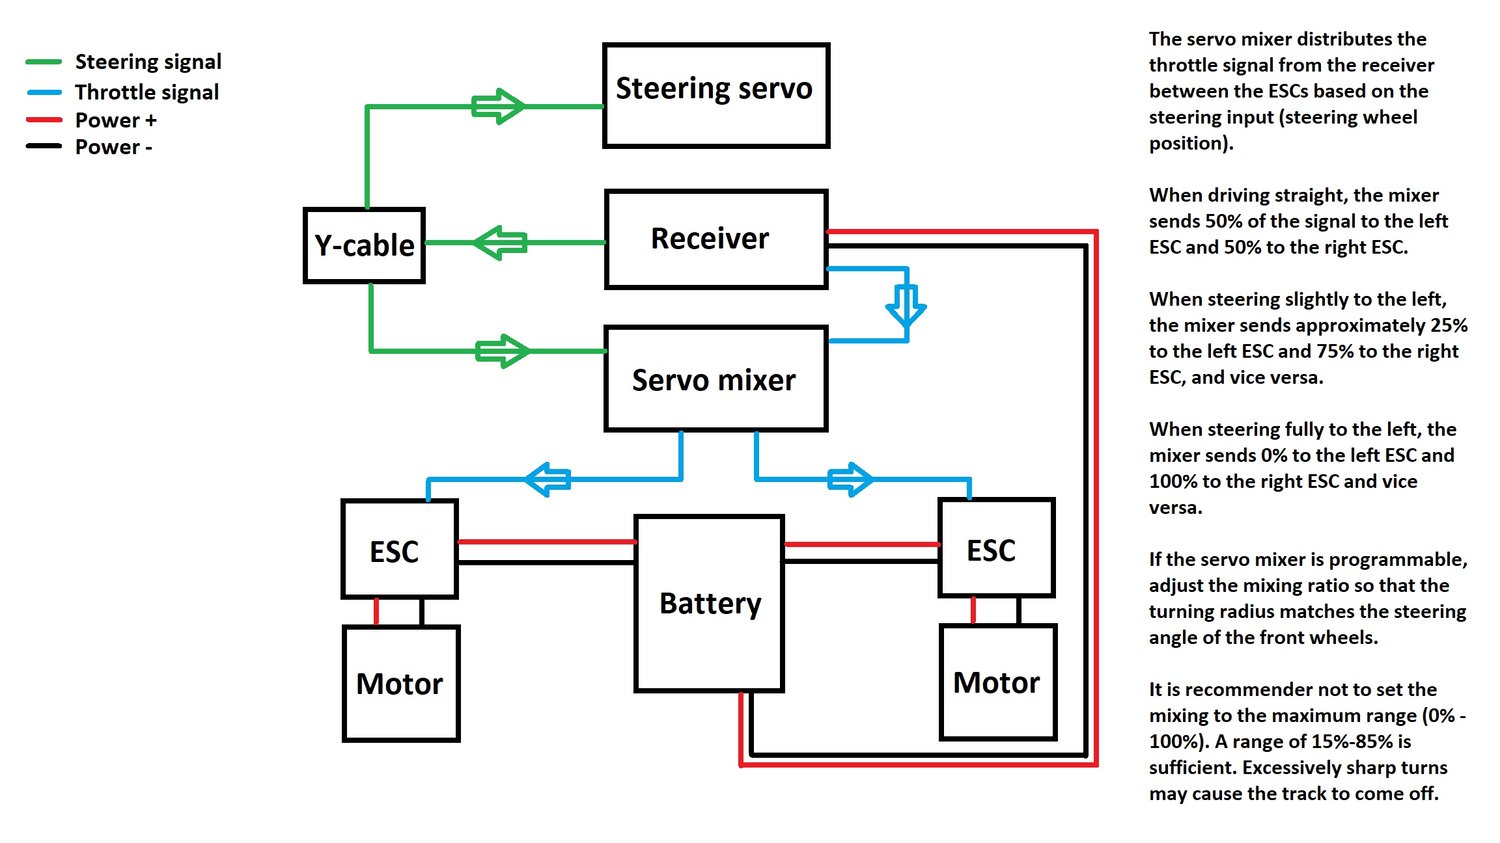
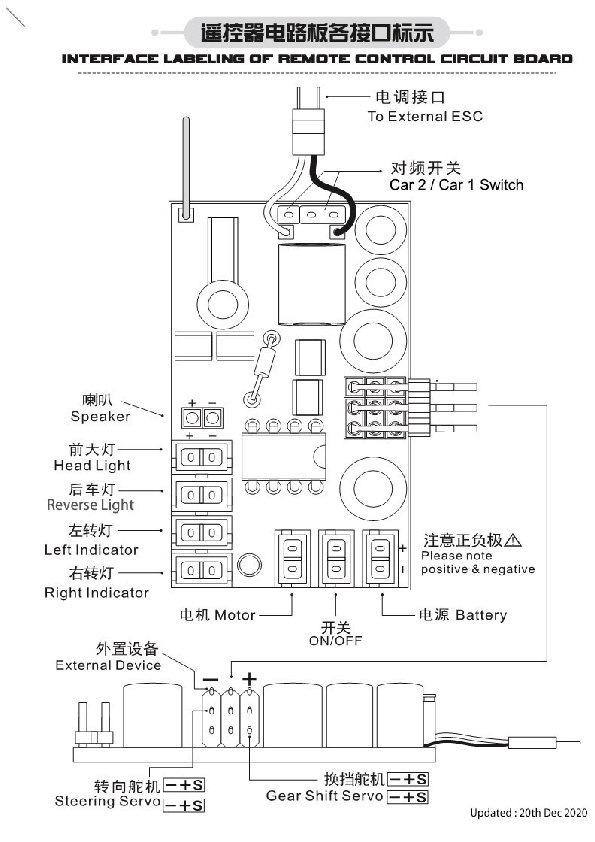
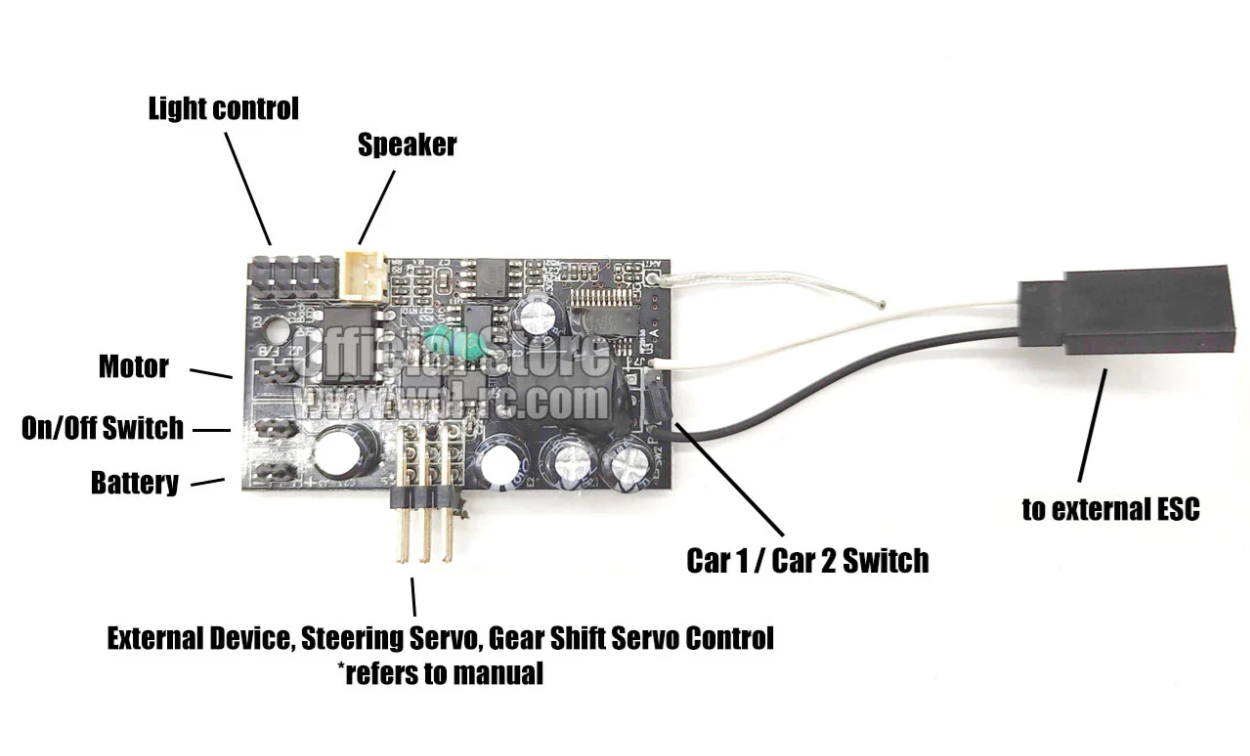
Connect the first JST-SH cable to the Battery connector on the receiver board according to the wiring diagram.

Connect it to the same battery that will also power the ESCs.

⚠️ Be careful with polarity!

Connect the “To External ESC” connector from the receiver board to the servo mixer throttle output.

Connect the second JST-SH cable to the ON/OFF connector and attach a small slide switch to it.

Connect the speaker according to the wiring diagram.

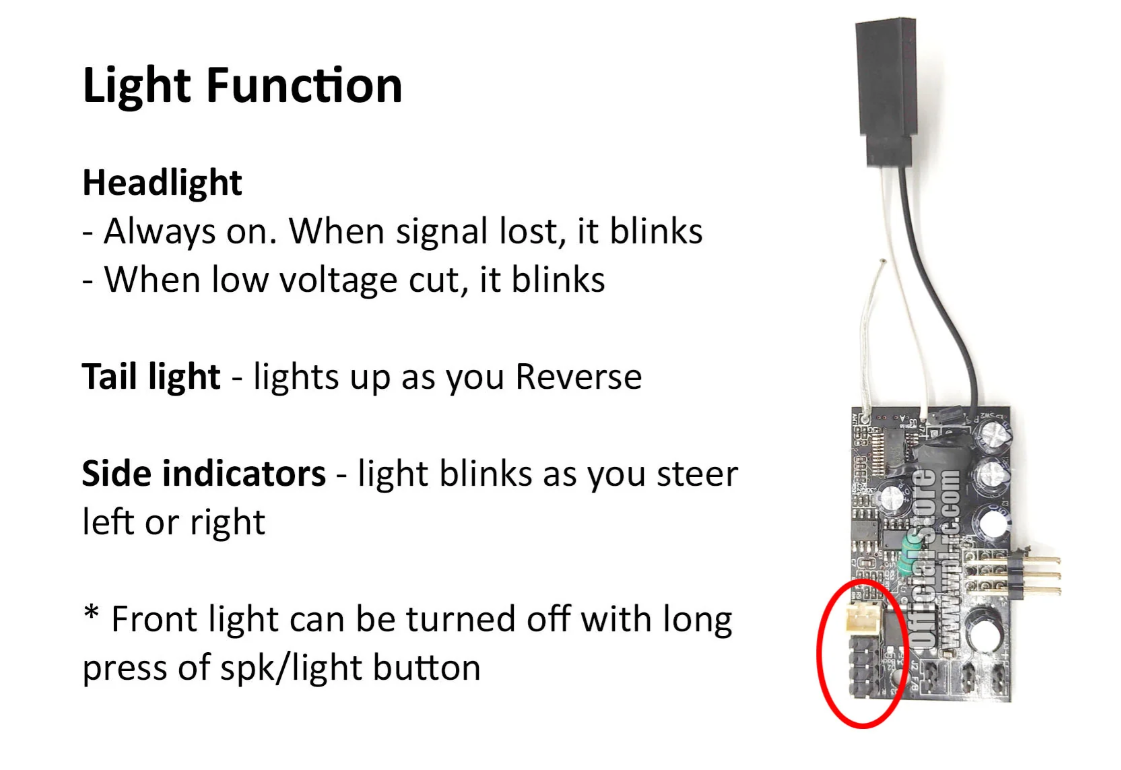
Connect the LED lights using the DuPont cables according to the diagram.

Connect the steering servo according to the diagram.

Leave the “Motor” connector on the receiver board empty.

This output is designed only for small motors.

For larger 1/10 scale models it is too weak and may damage or burn the receiver board.

This is why an external ESC is required.

Winch / Rotating Turret Setup

If your model uses a winch or a rotating turret, the setup is slightly more advanced.

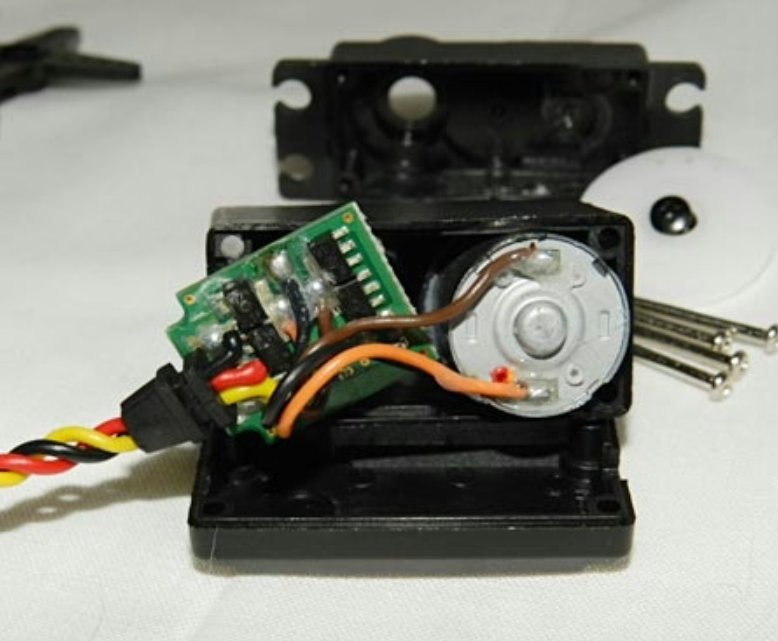
Take a 360° servo and remove the screws on the bottom cover. Carefully remove only the bottom cover.

⚠️ Be careful — the top cover may come loose easily as well.

Disconnect the motor wires and the wires connected to the internal control board. Remove the entire electronics board from the servo.

Next, take the original power wires and connect the positive (+) and negative (-) wires directly to the motor terminals.

Reassemble the servo.

Install the modified servo into the correct position for the winch or rotating turret and connect the servo power wires to the “External Device” output on the receiver.

The rotation is then controlled using the side lever on the transmitter.

Final Check

Carefully double-check all wiring before powering the model.

Once connected correctly:

The R.E.S. receiver handles:

  • lights
  • sound
  • steering servo control
  • winch/turret control
  • throttle signal

The ESC handles:

  • supplying power to the drive motors

The servo mixer handles:

  • power distribution between the motors